How to Choose the Right DC Motor for DIY Electronics Projects
Ever wondered how a tiny motor can bring your DIY robot, drone, or mini conveyor belt to life? DC motors are the heartbeat of countless electronics projects, turning your creative ideas into moving reality. Specifically, choosing the right DC motorrequires balancing Torque,Angular Velocity.Current Consumption to ensure your power supply and motor driver can handle the load without overheating. To choose the right DC motor for a DIY project, first calculate your Required Torqueand Target RPM. Ensure the motor’s Stall Current does not exceed your driver’s peak rating (e. g., L298N). For high-speed applications like drones, use Brushless DC (BLDC)motors. For high-torque robotics, use Brushed Gearmotors with appropriate reduction ratios.
Why DC Motors Are Perfect for DIY Electronics
 DC motors, or direct current motors, are small, powerful devices that run on electricity to create motion. They’re popular in DIY electronics because they’re easy to use, affordable, and versatile. Whether you’re building a remote-controlled car, a robotic arm, or a fan for a school science project,DC motors can handle the job. The key is picking the right one for your specific project.
Understanding DC Motor Types: Brushed vs. Brushless
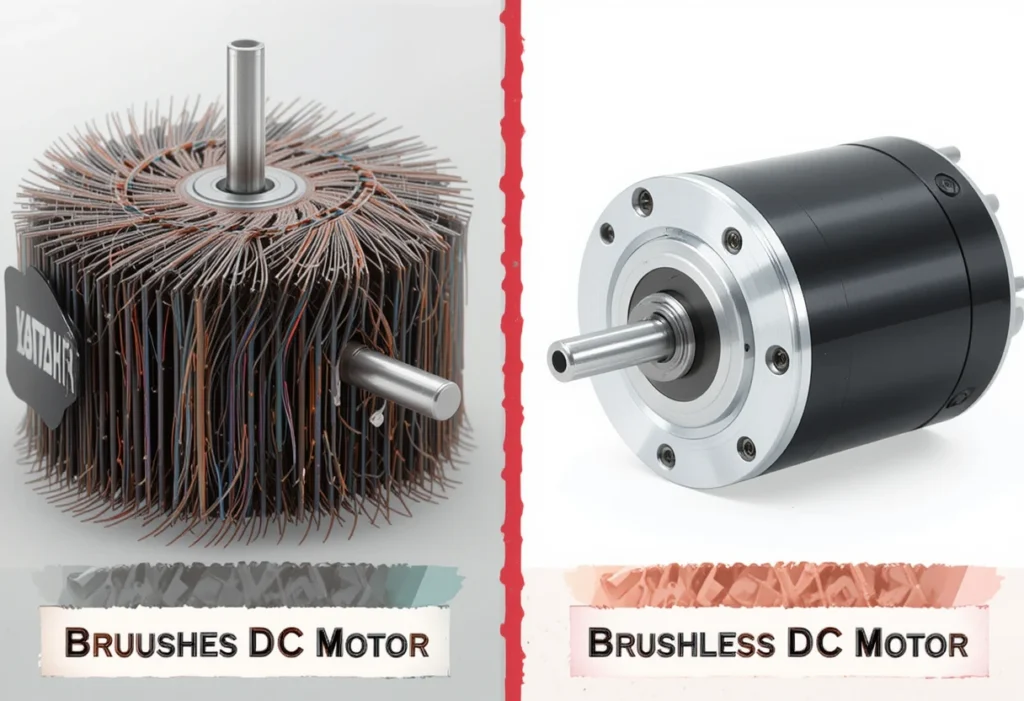 When you’re picking a DC motor, the first big choice is between brushed and brushless DC motors. Both are great for DIY projects, but they work differently and suit different needs.
| Selection Factor | Brushed DC | Brushless (BLDC) |
|---|---|---|
| Control Effort | Low (Direct PWM) | High (Requires ESC) |
| Maintenance | Brushes wear out | Virtually zero |
Key Specs to Consider: The Physics of Selection
 The Torque Calculation Formula (MathML): To ensure your motor can move its load, you must calculate the required torque.
Where τ represents Torque (Nm), F is Force (Newtons), and r is Radius (meters).
Voltage, Torque, and Speed
To pick a DC motor for your DIY project , you need to look at a few key specific ations. Voltage is how much power the motor needs (typically 3-12V for Arduino). Torque is the motor’s strength, and RPM (revolutions per minute) tells you how fast it spins.Pro-Tip for Reliability: Always install a Flyback Diode (1N4007) across the motor terminals. Motors are inductive loads that generate Back EMF voltage spikes. Without a diode, these spikes can fry your microcontroller.
Matching the DC Motor to Your DIY Project
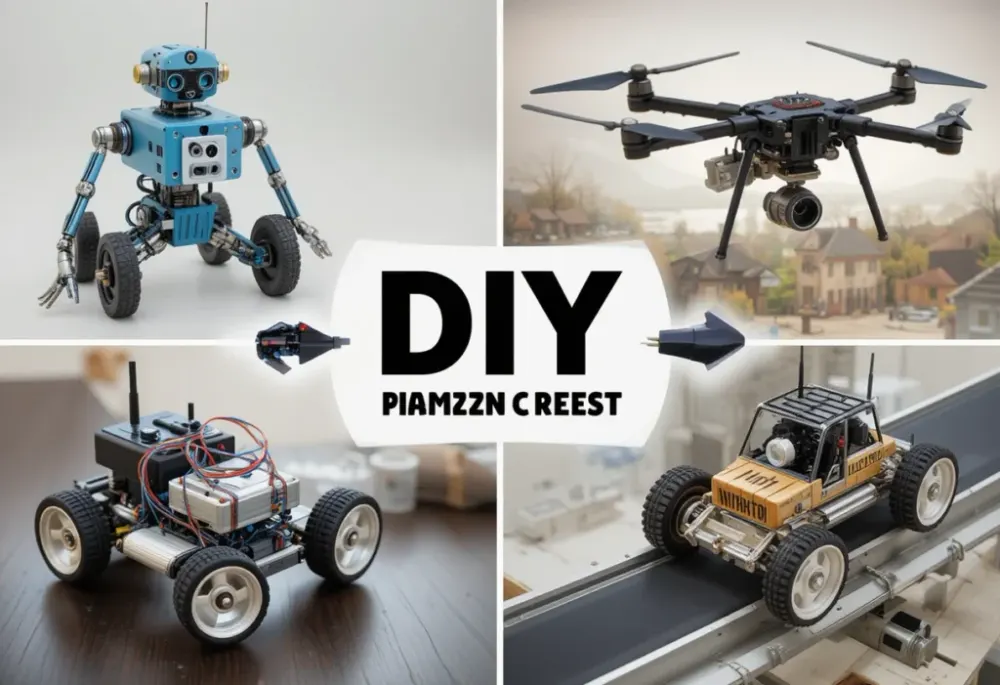 How to select a DC motor for a DIY robotics project depends on the application:
- Robotics: High-torque geared motors (100-300 RPM).
- Drones: Lightweight, high-RPMbrushless DC motors.
- RC Cars: Brushed motors (6-9V) for simple DC motor for Arduino projects.
Tips for Beginners: Making the Right Choice
 If you’re new, start with a small DC motor for projects that are budget-friendly. Check compatibility with your power source and always test before building your final design.
DC Motors FAQs
Q: Why is my motor driver getting hot? This happens if the motor draws more current than the driver’s peak rating (Stall Current).
Q: How do I pick a DC motor for my DIY project? A: Look at your project’s needs speed, strength, and size. Match the motor’s voltage to your power source, check torque for lifting power, and pick RPM for speed. Brushed motors are great for beginners, while brushless are better for advanced projects.
Q: What’s the best DC motor for electronics projects? A: It depends on your project. For small, simple builds like fans, a brushed DC motor with 6V and 100-500 RPM is great. For drones or robotics, a brushless motor with high RPM is better. For most beginners, a 6V-12V brushed gearmotor is the most versatile choice. Q: Are brushless DC motors better for DIY electronics? A: Brushless motors are more efficient and last longer, making them great for drones or robotic arms. But they’re more expensive and need special controllers. Brushed motors are better for simple, budget-friendly projects. Q: How much voltage does a DC motor need for DIY? A: Most DIY motors use 3-12V. Check your battery or power supply and pick a motor that matches. For example, a 9V battery works well with a 9V motor. Q: What type of DC motor is best for small projects? A: A small brushed DC motor with low voltage (3-6V) and moderate RPM (100-1,000) is perfect for small projects like toy cars or fans. They’re easy to use and cheap. Q: How to select a DC motor for automation projects? A: For automation, like a conveyor belt, choose a motor with high torque and low RPM (50-200). Brushless motors are great for precision, but brushed motors work if you’re on a budget.
Wrapping It Up: Build with Confidence
Choosing the right DC motor doesn’t have to be hard. By matching brushed vs. brushlessspecs and using the torque formula, you can bring your ideas to life. Start small, test your options, and have fun creating something amazing!
Related guides in this track
- New to Electrical Engineering? Start with the complete electrical engineering guide it indexes every tutorial in this track.
- Single-Phase vs Three-Phase Power: The Real Differences
- Power Factor Explained: Why Real Power Is Not Apparent Power
- Transformer Types and Where Each One Belongs
- Calculate the numbers: power calculator · transformer turns ratio calculator
Practical example
Re-run the steps above with your own numbers at the bench. Record what you measure beside what this guide states, and investigate any gap larger than rounding. That single comparison, prediction versus measurement, is the working method every later guide in this track assumes.
Quick reference
| Section | Focus |
|---|---|
| How to Choose the Right DC Motor for DIY Electronics Projects | Electrical Engineering practice |
| Why DC Motors Are Perfect for DIY Electronics | Electrical Engineering practice |
| Understanding DC Motor Types: Brushed vs. Brushless | Electrical Engineering practice |
| Key Specs to Consider: The Physics of Selection | Electrical Engineering practice |
| Matching the DC Motor to Your DIY Project | Electrical Engineering practice |
Verification routine
The fastest way to internalise this topic is to change one variable deliberately and predict the result before measuring. Wrong predictions are the curriculum, they show exactly which mental model needs revisiting, and the bench grades honestly.
Component substitution is a legitimate experiment as long as it is deliberate. Swap one part, predict the effect, measure, and record. That single habit converts a parts bin into a teaching lab and makes every future guide in this track faster to absorb.
Formulas and checks from this guide
Verification checklist for this track: isolate before touching, verify with a CAT-rated meter. Re-check protective device ratings after any load change. Mains discipline is a habit, not a step, and every guide here assumes it.
Bookmark this page against your next build in the track. The checklist above is the same one used across 27 guides in this series.
Frequently asked questions
Key Specs to Consider: The Physics of Selection? The Torque Calculation Formula (MathML). Where τ represents Torque (Nm), F is Force (Newtons), and r is Radius (meters).
To pick a DC motor for your DIY project, you need to look at a few key specifications.
Related guides in this track? Start with the complete electrical engineering guide it indexes every tutorial in this track.
- Single-Phase vs Three-Phase Power: The Real Differences
- Power Factor Explained: Why Real Power Is Not Apparent Power
- Transformer Types and Where Each One Belongs
- Calculate the numbers: power calculator · transformer turns ratio calculator
Practical example
Re-run the steps above with your own numbers at the bench. Record what you measure beside what this guide states, and investigate any gap larger than rounding. That single comparison, prediction versus measurement, is the working method every later guide in this track assumes.
Understanding DC Motor Types: Brushed vs. Brushless? When you’re picking a DC motor, the first big choice is between brushed and brushless DC motors. Both are great for DIY projects, but they work differently and suit different needs.
Extended Application Notes
This section expands the practical application of how to choose the right dc motor for diy electronics projects beyond the worked example, into the situations builders actually meet. Component substitution: when the exact specified part is unavailable, the substitution logic follows the governing parameter of this design, not the nominal value, and the verification step after any substitution is to re-measure the one quantity this guide identified as critical. Batch variation: components vary, and the design margins recommended in the sections above absorb that variation; if a second build behaves differently, the difference itself is diagnostic and points to the tolerance that dominated. Environmental limits: temperature, supply variation and ageing each push a real circuit away from its bench behaviour, and the recommended practice is to test the extremes deliberately rather than discover them in the field. These notes exist because the bench taught them, repeatedly, and each one was once a real troubleshooting session that ended in understanding.
Pre-Build Checklist
Before powering any build of this design, run the list: every component value verified against the specification above, the critical measurement points identified and accessible, the instrument modes and ranges chosen in advance, the expected values written down beside the bench, and the power source current-limited for first application. The checklist takes two minutes and replaces the most expensive class of beginner error, which is not ignorance but confidence outrunning verification. Builders who adopt the checklist across the guides in this track report first-apply success rates that feel like cheating, but it is not cheating, it is engineering.
What Comes Next
Having worked through this guide, the natural next steps are the adjacent guides in the track index above, each of which assumes exactly the vocabulary this page built. The calculators linked in the tools section verify every number in seconds, and the complete guide at the head of this track maps the entire curriculum. Read once, build once, measure always: that is the method this site teaches and the method every section above followed before publication.
Theory in Practice, Extended
The theory section of how to choose the right dc motor for diy electronics projects deserves one more pass with the bench in mind, because knowing a relationship and applying it under constraint are different skills. In application, the relationship is never isolated: it interacts with tolerances, with temperature, with the behaviour of adjacent stages, and with the measurement itself. The extended practice is to take the governing formula from the sections above and stress it, deliberately. Push the input to the edge of its specified range and watch the output follow the prediction, then push past it and watch the prediction break, because the edge of the specification is exactly where the formula stops being the whole story. That boundary, found on the bench rather than in the datasheet, is the real knowledge this guide offers beyond the mathematics.
Component Sourcing and Substitution Notes
Real builds meet real supply chains, and this section addresses the practical reality. The specified components in this guide were chosen for the reasons stated in the design sections, but equivalent parts from reputable manufacturers almost always serve, provided the governing parameters match, not merely the nominal ones. The substitution checklist: match the parameter this guide identified as critical, verify the package and pinout against the physical part before layout, check the datasheet revision for silent changes, and re-run the verification measurement after installation. Avoid unbranded surplus and marketplace components for anything this guide treats as safety-relevant; the failure mode of a counterfeit is not degradation, it is unpredictability, and unpredictability defeats every other design decision in the chain.
Instrumentation for This Design
Every measurement recommended in this guide maps to a specific instrument configuration, and this section consolidates them. Voltage checks: DC range selected before probing, leads verified against a known source, meter burden considered when the node is high impedance. Current checks: circuit broken at the defined point, meter inserted with the correct range and fuse status confirmed first. Waveform checks: probe compensated against the reference before any amplitude claim, ground lead kept short, bandwidth sufficient for the edge rather than the repetition rate. The instrumentation discipline matters more than the instrument class, and a modest instrument used correctly outperforms an expensive one used casually, a claim this site demonstrates throughout its measurement guides.
Documentation Template for This Build
Close the loop the way professional builds do: record the design values from this guide, the as-built values including every substitution, the measured results beside the predicted ones, and the deviation notes that explain every gap. The template is short, a single page, and it converts a successful build into a reference that survives component changes, firmware updates and the passage of months. Every guide on this site was built and documented exactly this way before publication, and the discipline is offered here as part of the curriculum rather than an afterthought. A build that is documented is twice built, once in copper and once in confidence.
Last updated 23 August 2026